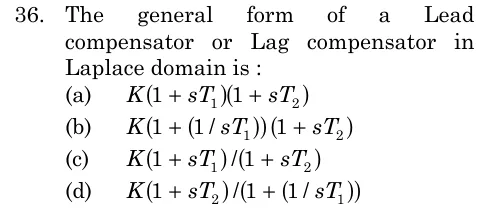
The general form of a Lead compensator or Lag compensator in Laplace domain is :
- (A)
- (B)
- (C)
- (D)

The general form of a Lead compensator or Lag compensator in Laplace domain is :
ANSWER
The general form is , which is option (c).
Official answer: CSource: ISRO's final answer key of 15 May 2026
A first-order lead or lag compensator has one zero and one pole, with a gain: . The zero is at and the pole at .
If , the zero at is closer to the origin than the pole at . The phase of is , so the network adds phase lead: a lead compensator.
If , the pole is closer to the origin than the zero. The phase is negative, so the network adds phase lag: a lag compensator.
Option (a), , has two zeros and no pole. It is not a lead or lag network.
Option (b), , contains a integral term. It is a PI factor multiplied by a zero factor, a PID-type form.
Option (d) can be rewritten as . This has a zero at the origin, a second zero and a pole, so it is not the standard single-zero, single-pole form.
Only option (c), a gain times one zero factor over one pole factor, is the general form of both the lead and the lag compensator.
KEY IDEA
Lead and lag compensators share one form, a gain with a single zero and a single pole: . Lead when , lag when .
WATCH OUT FOR
Picking a form with a term or with two zero factors. Those are PI or PID style controllers, not lead or lag networks, which need exactly one zero and one pole.
From the ISRO EC 2025 paper. Every question of this paper · The full paper (PDF, ISRO) · All 3 ISRO Compensators & PID questions, with notes