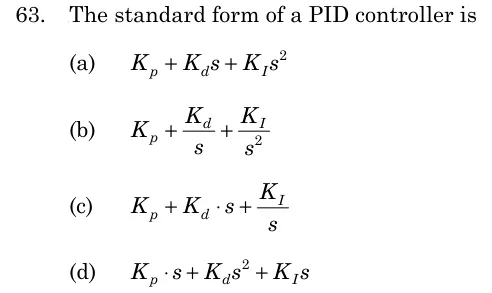
The standard form of a PID controller is
- (A)
- (B)
- (C)
- (D)

The standard form of a PID controller is
ANSWER
The standard PID form is , which is option (c).
Official answer: CSource: ISRO's revised and final answer key of 16 February 2024
A PID controller acts on the error with three parts: proportional, integral and derivative. Its output is the sum of the three.
Proportional action: , so its transfer function is .
Integral action: . Integration in time corresponds to division by , so this part is .
Derivative action: . Differentiation in time (zero initial conditions) corresponds to multiplication by , so this part is .
Adding the three parts: This is option (c).
Option (a) has : multiplying by means differentiating twice, not integrating. Option (b) has and : dividing by means integrating, so the derivative term is wrong and the integral term is a double integral. Option (d) equals , which has no integral term and no constant proportional term.
KEY IDEA
In the Laplace domain, differentiation is multiplication by and integration is division by , so a PID controller is .
WATCH OUT FOR
Swapping the roles of and , putting the derivative gain over or the integral gain times a power of , as in options (a) and (b).
From the ISRO EC 2023 paper. Every question of this paper · The full paper (PDF, ISRO) · All 3 ISRO Compensators & PID questions, with notes