
IAE Academy

GATE 2025 IN Q.47: solution and answer

GATE 2025 · INQ.47 · 2 marks · MCQ

The figure shows a closed-loop system with a plant and a lead compensator . The compensator is designed to place the dominant closed-loop poles at . From the following options, choose the phase lead that the compensator needs to contribute.
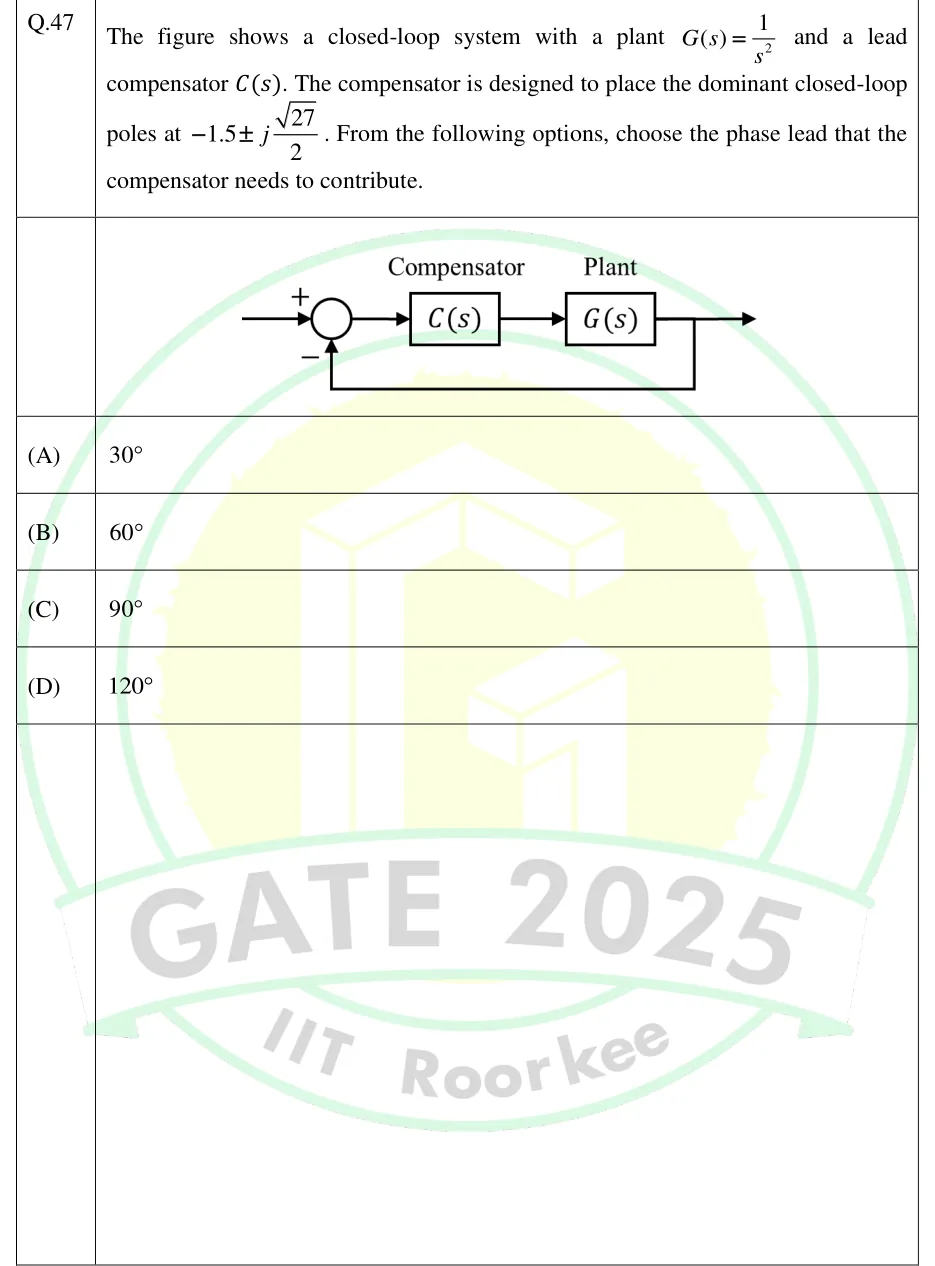
GATE 2025 IN question 47: Unity negative feedback loop.Tap to open full size
Figure from the GATE 2025 IN paper. It is part of the question.
Figure description

Unity negative feedback loop. The reference input enters a summing junction with a + sign on the input and a - sign on the feedback path. The junction output feeds a block labelled 'Compensator' C(s), which feeds in cascade a block labelled 'Plant' G(s). The output of G(s) is the system output and is also fed back directly (gain 1) to the - terminal of the summing junction.

  1. (A)

  2. (B)

  3. (C)

  4. (D)

Answer and solution

ANSWER

The lead compensator must contribute at . The answer is (B).

Official answer: BSource: Official answer key, GATE 2025 IN (IIT Roorkee)

  1. Desired closed-loop pole: . Since , its distance from the origin is , so and .

  2. Angle of the vector drawn from a pole at the origin to , which lies in the second quadrant: .

  3. Plant phase at : has a double pole at the origin, and each pole contributes , so .

  4. Root-locus angle condition: for to be a closed-loop pole of the unity-feedback loop, .

  5. Required compensator phase: . (Using instead gives , which is the same direction, .) The compensator must supply a phase lead of .

  6. Check: without compensation, gives , so the locus lies only on the axis. The locus has to be pulled into the left half-plane, and a positive (lead) angle at is what does that. This agrees with option (B).

KEY IDEA

Use the root-locus angle condition at the desired pole. Every open-loop pole at the origin contributes , measured from the positive real axis. The compensator has to supply whatever angle is still needed to bring the total to an odd multiple of . Here that is .

WATCH OUT FOR

One mistake is to measure the pole angle from the negative real axis () instead of from the positive real axis (). The plant phase then comes out as , which wrongly calls for (a lag). Another is to count the double pole at the origin only once. A third is to pick (D) because that is itself, not the deficit the compensator has to make up.

From the GATE 2025 IN paper. Every question of this paper · Download the full paper · All 10 Compensators & PID questions, with notes

More Compensators & PID questions