
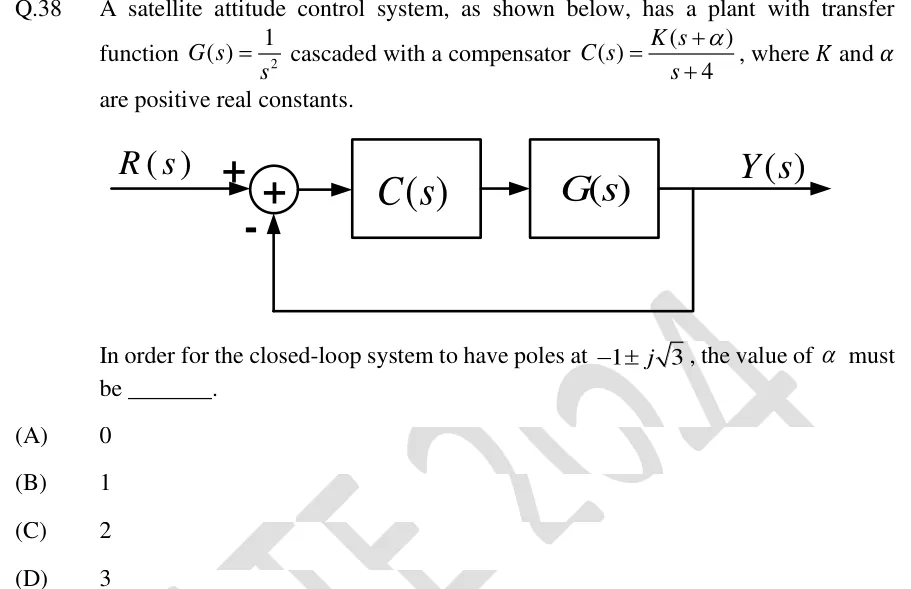
A satellite attitude control system, as shown below, has a plant with transfer function cascaded with a compensator , where and are positive real constants.
[Figure: unity negative feedback loop with and in cascade]
In order for the closed-loop system to have poles at , the value of must be ________.
 Tap to open full size
Figure description
Block diagram: input R(s) enters a summing junction with sign + on the reference input and sign - on the feedback input. The junction output feeds block C(s), which feeds block G(s) in cascade; the output of G(s) is Y(s). Y(s) is taken off and fed back directly (unity gain, no block) to the - input of the summing junction. So it is a unity negative feedback system with forward path C(s)G(s).
- (A)
0
- (B)
1
- (C)
2
- (D)
3